Print your own Huebot
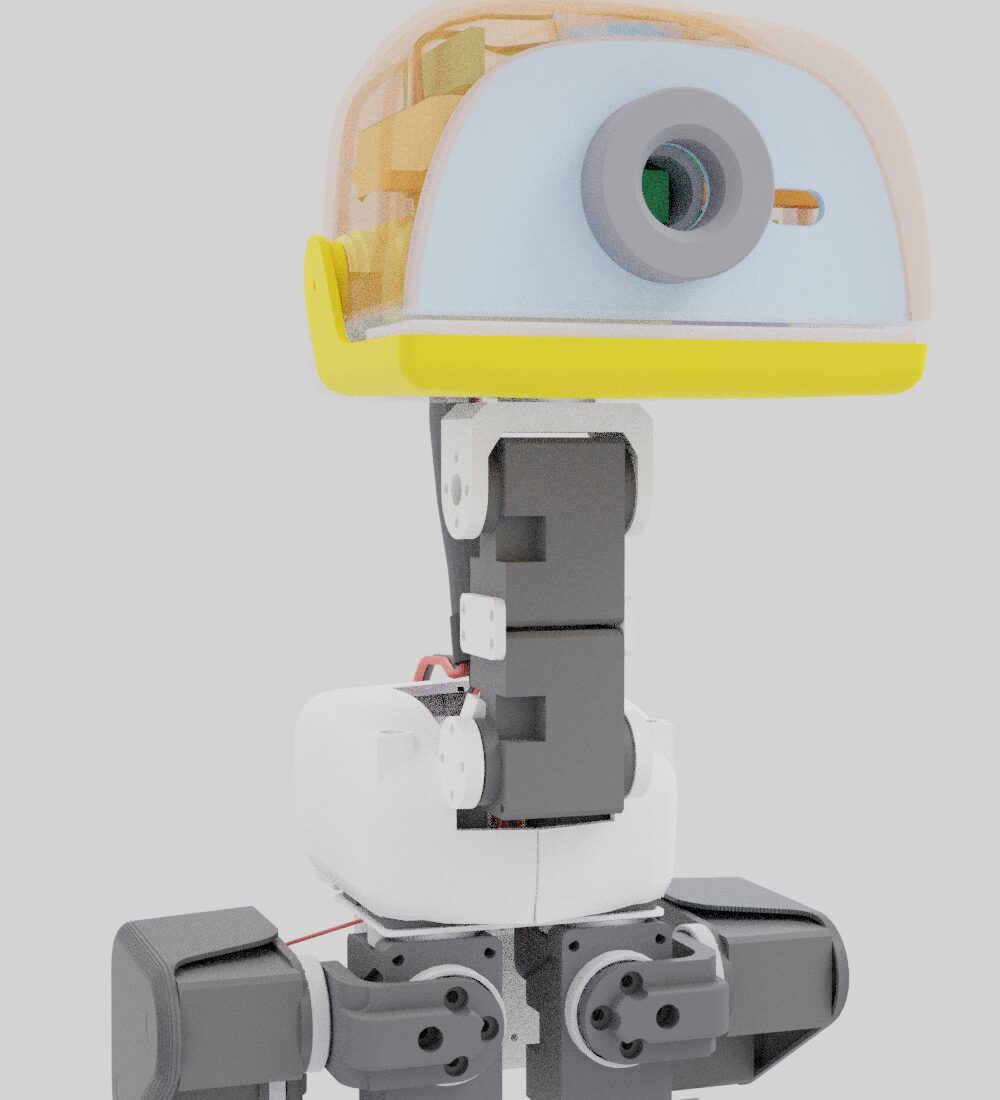
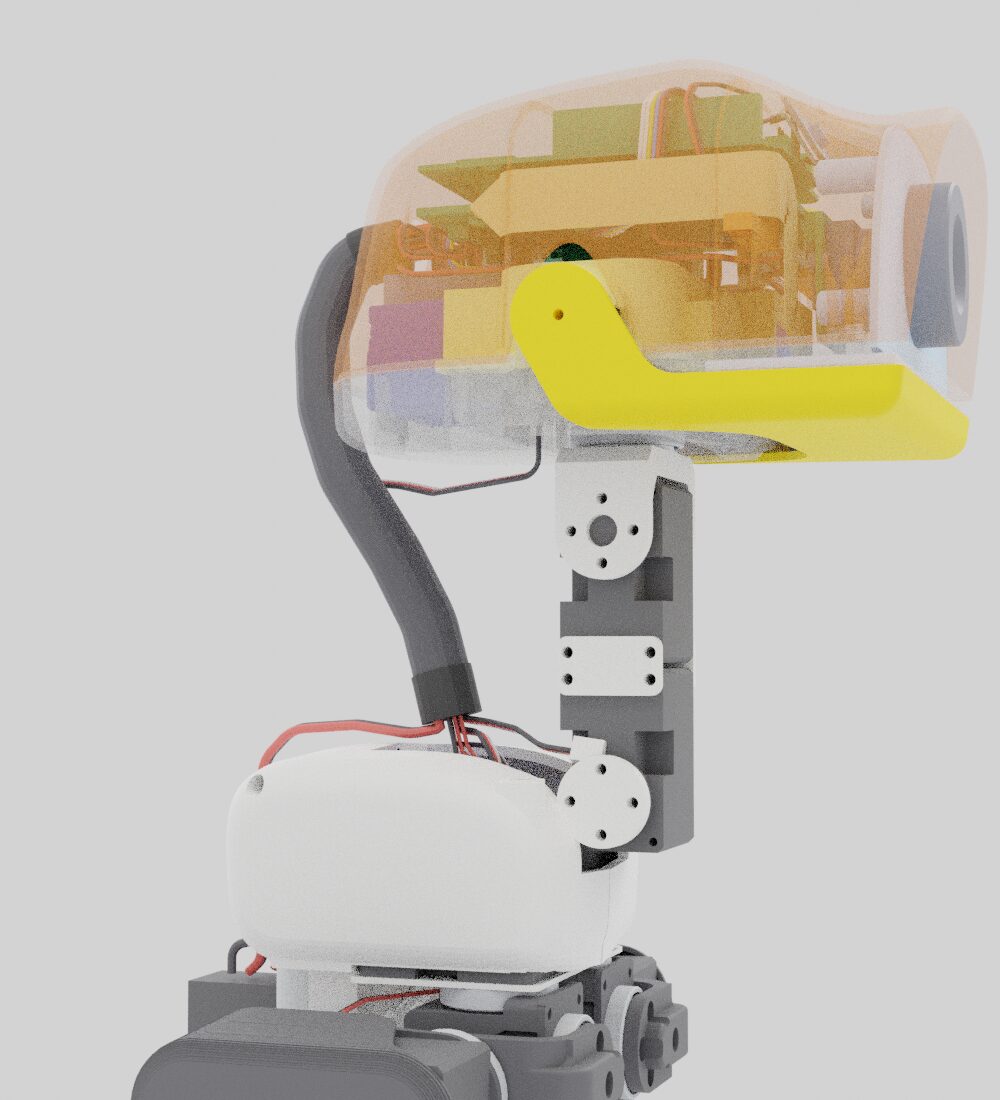
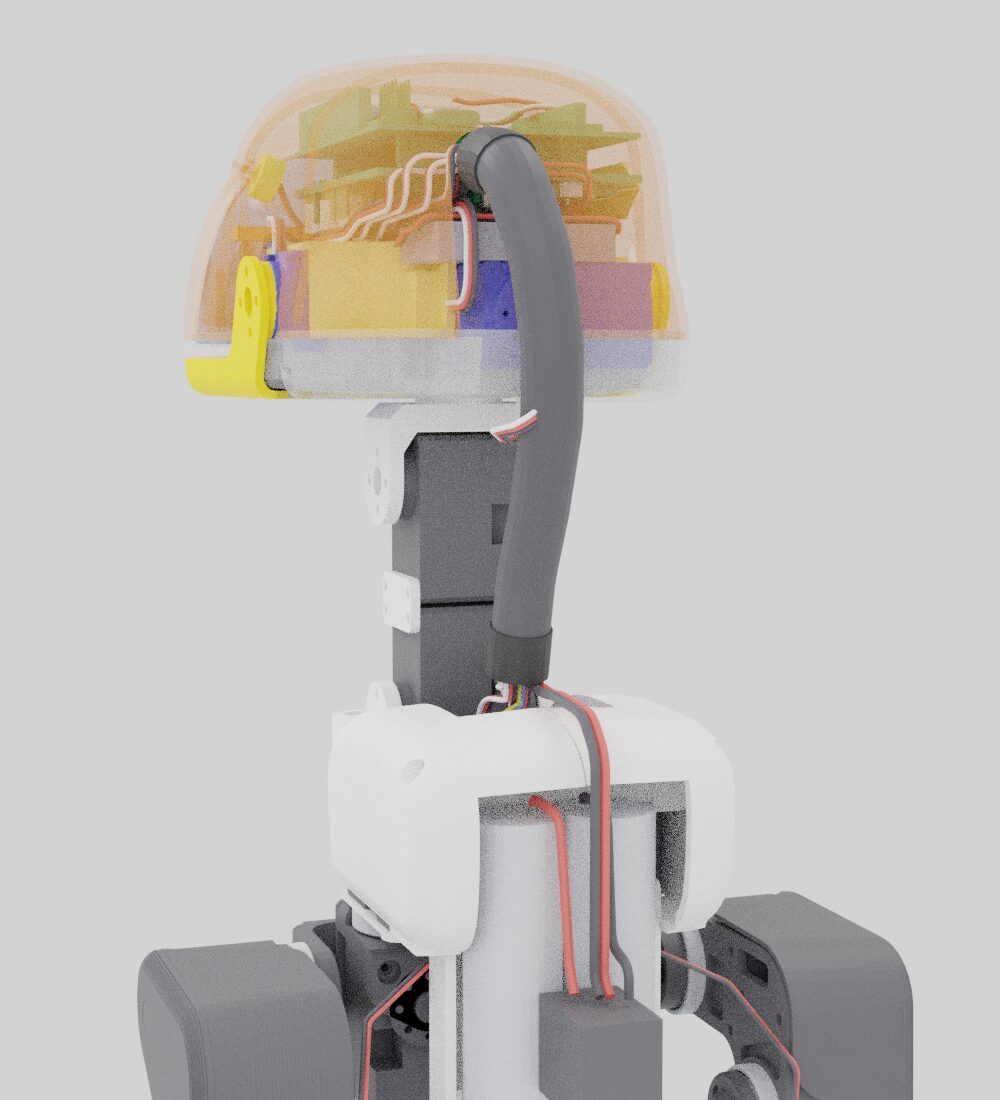
Every printed part of Huebot, the walking robot we build, as free STL files. Every part is modelled in our own CAD system from measurements of the robot we print and walk. The trunk base and battery holder are the reinforced versions, the legs take Feetech HD-1910 servos, and the top head shell holds an Arduino UNO Q.
30 STL files, 37 printed pieces, millimetres. Licence CERN-OHL-W-2.0: print, change, share and sell.
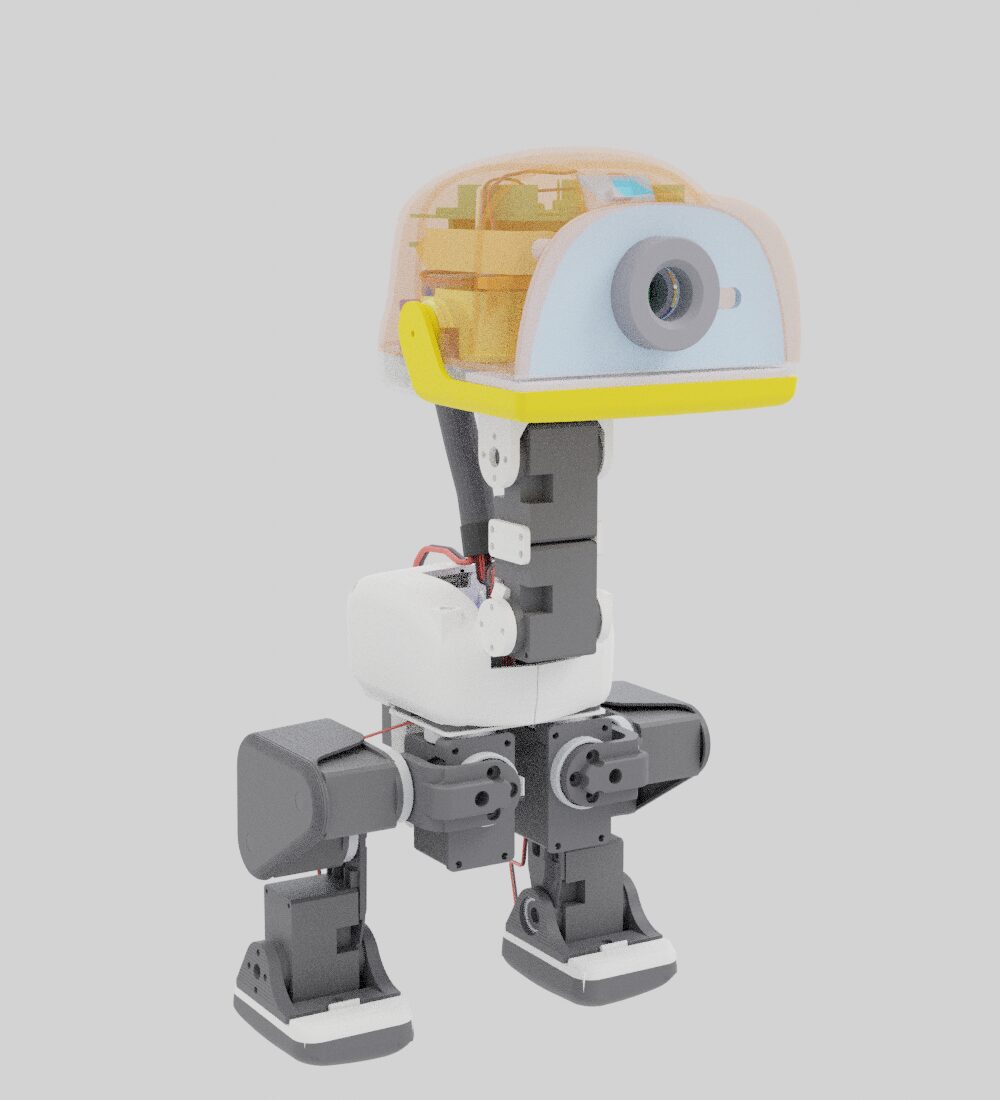
Print it on our farm
No printer? Upload these STL files at ce-net.com/print/order and our print farm prints them for the cost of printing: one build plate is $39, and shipping is shown at checkout. You get a photo of the plate before it ships.
Views
Parts for one robot
| File | Qty | Size mm |
|---|---|---|
| body-trunk-shell-left.stl | 1 | 33.7 × 80.9 × 41.8 |
| body-trunk-shell-right.stl | 1 | 31.8 × 80.9 × 41.7 |
| body-trunk-base.stl | 1 | 58.5 × 37.3 × 3.0 |
| body-power-support.stl | 1 | 55.8 × 18.3 × 83.1 |
| body-pcb-locker.stl | 1 | 54.0 × 3.8 × 6.6 |
| body-neck.stl | 2 | 2.0 × 20.0 × 11.0 |
| body-neck-pitch.stl | 1 | 35.0 × 18.0 × 27.7 |
| leg-hip-bracket.stl | 2 | 32.4 × 34.5 × 19.0 |
| leg-yaw2roll.stl | 2 | 23.0 × 25.8 × 20.5 |
| leg-bearing-roll.stl | 2 | 23.0 × 3.5 × 40.0 |
| leg-upper-left.stl | 1 | 28.0 × 47.6 × 60.9 |
| leg-upper-right.stl | 1 | 28.0 × 47.6 × 60.9 |
| leg-upper-rigidity-plate.stl | 2 | 2.0 × 45.2 × 58.5 |
| leg-shin.stl | 2 | 7.6 × 20.0 × 58.0 |
| leg-ankle-left.stl | 1 | 39.5 × 36.5 × 25.5 |
| leg-ankle-right.stl | 1 | 39.5 × 36.5 × 25.5 |
| leg-foot-left.stl | 1 | 40.1 × 54.0 × 16.9 |
| leg-foot-right.stl | 1 | 40.1 × 54.0 × 16.9 |
| leg-sole-left.stl | 1 | 41.1 × 54.0 × 12.9 |
| leg-sole-right.stl | 1 | 41.1 × 54.0 × 12.9 |
| head-bottom-shell.stl | 1 | 91.7 × 116.7 × 20.1 |
| head-top-shell-unoq.stl | 1 | 91.8 × 122.7 × 58.8 |
| head-unoq-front-bracket.stl (2 pieces in one file) | 1 | 79.3 × 5.0 × 9.1 |
| head-face.stl | 1 | 87.6 × 12.5 × 44.6 |
| head-jaw.stl | 1 | 91.2 × 68.7 × 29.5 |
| head-jaw-soft.stl | 1 | 87.6 × 32.1 × 8.3 |
| head-soft-mouth-top.stl | 1 | 87.7 × 32.6 × 3.1 |
| head-eye-ring.stl | 1 | 30.0 × 9.5 × 30.0 |
| head-m12-lens-holder.stl | 1 | 24.0 × 14.8 × 16.0 |
| head-motor-support.stl | 1 | 73.5 × 54.2 × 18.8 |
Print settings
- PLA for every part. TPU 95A also works for the two soft mouth parts.
- Brim always, 5 mm, on every PLA part.
- 0.4 mm nozzle, 0.2 mm layers, 3 walls, 15 to 20 % infill. Tree supports on the build plate only, where the slicer asks.
- Print the bottom head shell flat side down, as modelled. Lay the other parts flat in your slicer.
Screws
Cross pan head (PH0), machine thread, black: M2×5 × 111, M2×8 × 22, M2.5×6 × 5 (each thigh takes 2 into its servo). Plus 5 M2 brass hex standoffs (female-male, 6 mm body, 3 mm thread) with 5 M2 washers.
Also needed: 15 Feetech HD-1910 servos, an Arduino UNO Q with its hat, a 2S 18650 pack with a switch, and bearings: 11 MR1622-ZZ (22×16×4 mm) and 2 MR6700 (15×10×3 mm).
Licence
Our own design, modelled in our own CAD system. The reinforced trunk base has motor-screw ears with 2.6 mm walls instead of 1.4 mm; the reinforced battery holder adds thicker flange ears, 45° root gussets and a centre web. The upper legs carry 2 mm rigidity plates.
These files are open hardware under CERN-OHL-W-2.0: print, change, share and sell them. If you share changed versions of the files, share them under the same licence.